 Image credit: TTCO authors. Thumbnail cropped from robot experiments.
Abstract
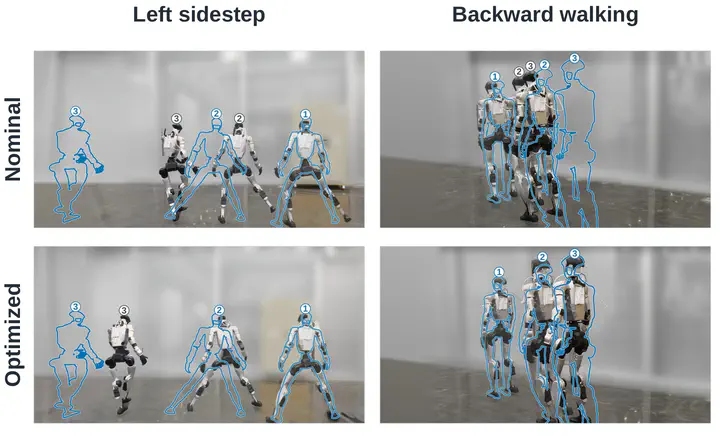
Test-Time Command Optimization (TTCO) improves humanoid motion execution while keeping the behavior foundation model frozen. It searches for commands through closed-loop simulations of the model and robot dynamics, reducing the mismatch between desired and executed trajectories. Across three foundation models, optimization reduces simulated mean global body-position error by 79–84%. The work also studies how to allocate test-time computation and generates controller-specific action labels from recorded robot trajectories without access to their original teleoperation commands. These labels support high-level loco-manipulation learning and demonstration reuse across controllers.
Type
Publication
arXiv preprint, 2026