SMART: Zero-Shot Sim-to-Real Articulated Object Manipulation via Large-Scale Synthetic Pretraining
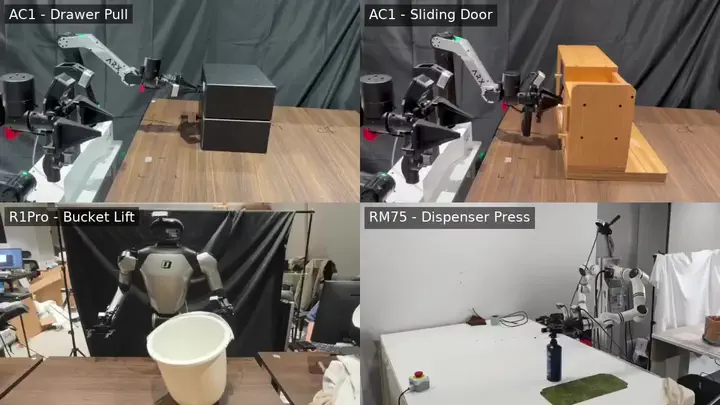 Image credit: SMART authors. Thumbnail cropped from robot experiments.
Abstract
SMART scales articulated-object manipulation learning through synthetic demonstrations. Its articulation-aware simulator combines part semantics, constrained motion generation, and agentic task creation with distributed data synthesis. The resulting SMART-Data contains over one million demonstrations covering 44 atomic task types, five robot setups, and 2,507 articulated objects. Pretraining a vision-language-action model on this corpus improves simulation performance and enables zero-shot transfer to real-world articulated-object manipulation. The results demonstrate how large-scale synthetic supervision can support contact-rich tasks that are expensive to demonstrate on physical robots.
Type
Publication
arXiv preprint, 2026