LocoManiLab: A Unified Testbed for Data, Policies, Controllers, and Deployment in Humanoid Loco-Manipulation
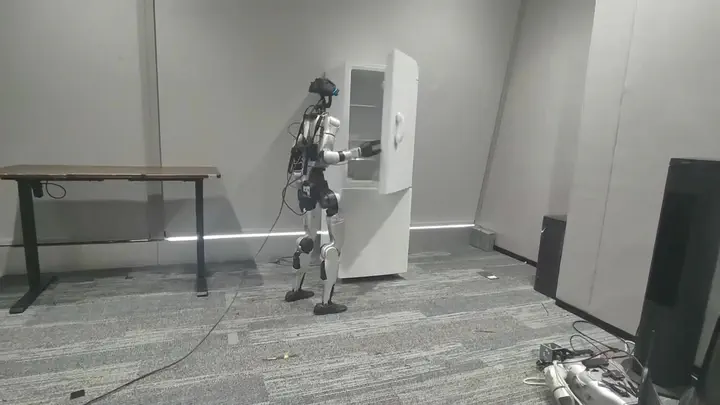 Image credit: LocoManiLab authors. Thumbnail cropped from robot experiments.
Abstract
LocoManiLab integrates data collection and generation, policy training, evaluation, and physical deployment for humanoid loco-manipulation. It provides 234 atomic and compositional tasks across five household scene categories, supported by 51.5 hours of simulated teleoperation. Evaluations compare twelve policies under a shared controller and study policy behavior across five controllers, demonstration scales, data mixtures, unseen tasks and scenes, and visual perturbations. Motion generation expands the data pipeline, while matched simulation and real-world task setups support physical validation. Similar policy rankings across the two domains provide evidence for the usefulness of simulation-based evaluation.
Type
Publication
arXiv preprint, 2026