Abstract
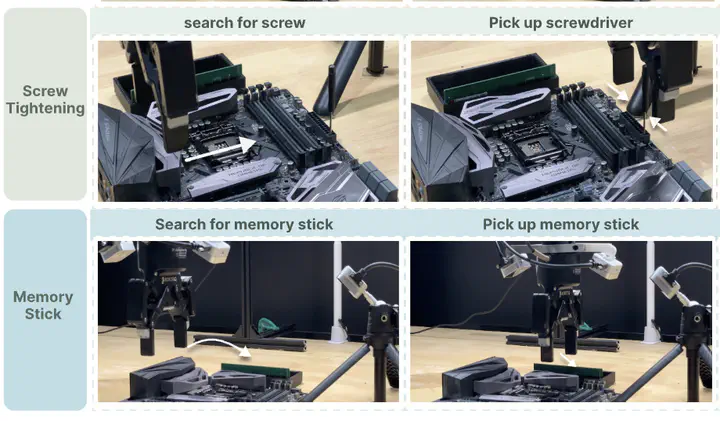
We study graph-reweighted behavior cloning with human interventions for precise robotic manipulation.
Type
Publication
In Annual Conference on Robot Learning (CoRL), 2026
We study graph-reweighted behavior cloning with human interventions for precise robotic manipulation.