Conference
In Annual Conference on Robot Learning (CoRL), 2026
Real-time text-driven humanoid motion generation and control using a two-level diffusion-and-tracking architecture (TextOp).

In Annual Conference on Robot Learning (CoRL), 2026
We introduce Pro-HOI, a generalizable framework for robust humanoid loco-manipulation via perceptive root-guided control.

In Annual Conference on Robot Learning (CoRL), 2026
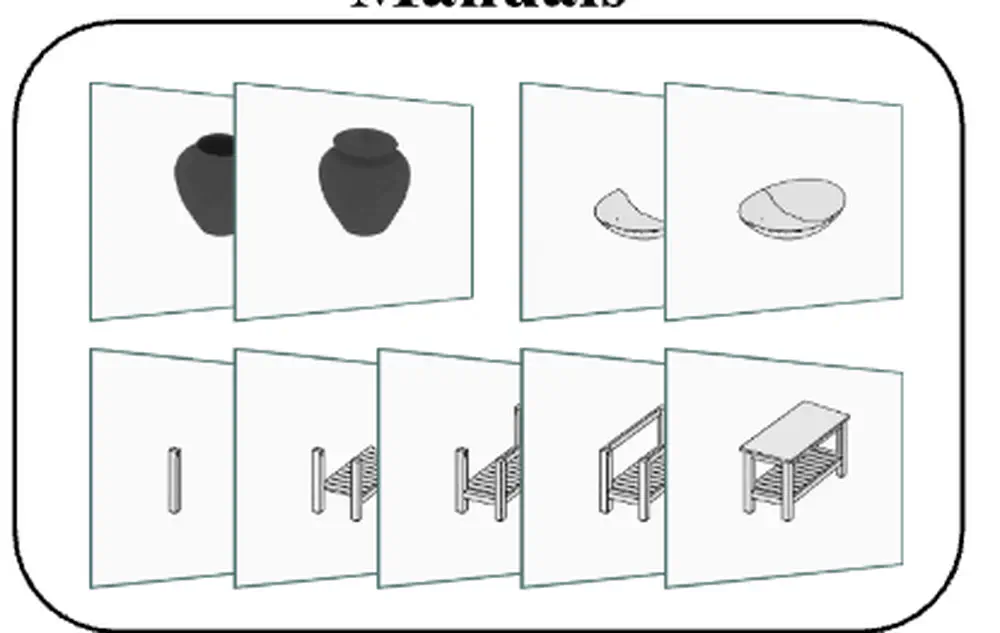
AssemLM introduces a spatial multimodal LLM and AssemBench to advance 3D reasoning and 6D pose prediction for robotic assembly.
In Annual Conference on Robot Learning (CoRL), 2026
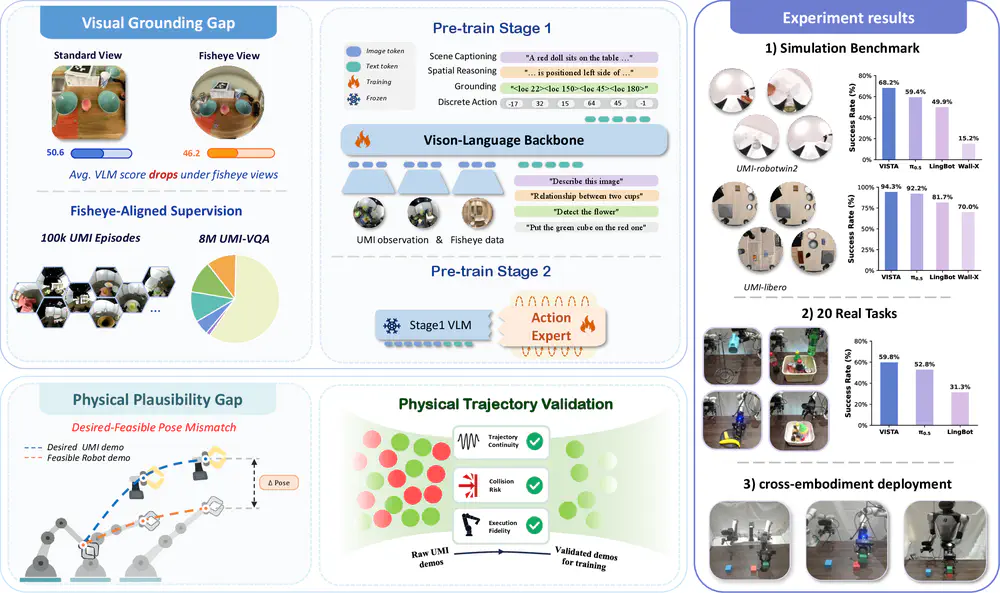
VISTA aligns UMI fisheye perception and physically validates trajectories to improve VLA training across simulation and real-world manipulation.
In Annual Conference on Robot Learning (CoRL), 2026
We introduce PRTS, a New Generation of Reinforcement Learning-Native Robotic Vision-Language-Action(VLA) foundation model.

In Annual Conference on Robot Learning (CoRL), 2026
Graph-reweighted behavior cloning with human interventions for precise robotic manipulation.
